Underwater ROV · assembly, custom payloads, training
BlueROV2, assembled for the work ahead
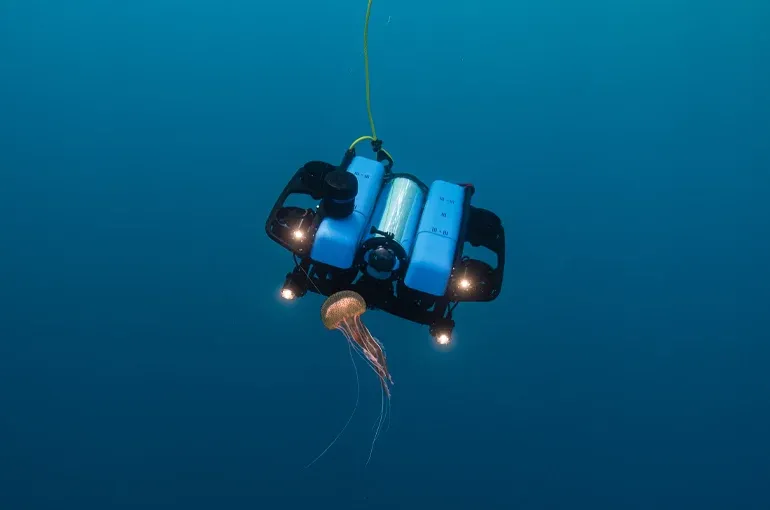
BlueROV2 is a configurable underwater ROV for inspection, research, payload integration, and advanced subsea missions. Sweep Deep can assemble, customise, test, train, and support the system around a real operating environment.
An underwater platform that can evolve
BlueROV2 is a high-performance, highly configurable platform with six- and eight-thruster options, open-source software, and a broad accessory ecosystem. It arrives partly assembled, giving teams a useful foundation for understanding, maintaining, upgrading, and modifying their system over time.
Where BlueROV2 fits
Sweep Deep can tailor the vehicle, payload, operator workflow, and support plan to the mission and environment.
Inspection and investigation
Configure cameras, lighting, sonar, tether, and operating workflow for subsea inspection or investigation tasks.
Research and monitoring
Integrate suitable sensors and data workflows for scientific, environmental, and marine research missions.
Custom payload missions
Plan grippers, sonar, cameras, samplers, payload skids, or mission-specific tooling around the task.
Assembly and operator support
Get help with assembly, configuration, testing, troubleshooting, training, maintenance, and handover.
BlueROV2 components and support
Sweep Deep can help specify and support payload skids, Ping sonar and altimeter options, spares, Fathom X tether interfaces, Ethernet switching, thrusters, lights, grippers, and speed controllers. Final configuration and availability are confirmed during project scoping.
- Payload skid and custom tooling
Payload skid and custom tooling
- Plan mounting, integration, balance, power, control, and testing for mission-specific payloads.
Plan mounting, integration, balance, power, control, and testing for mission-specific payloads.
- Sonar, altimetry, and sensing
Sonar, altimetry, and sensing
- Scope Ping sonar, altimeter, cameras, lighting, and other sensors for visibility, navigation, measurement, or data capture.
Scope Ping sonar, altimeter, cameras, lighting, and other sensors for visibility, navigation, measurement, or data capture.
- Tether and communications
Tether and communications
- Configure Fathom X, Ethernet switching, tether interfaces, and topside communications around the deployment.
Configure Fathom X, Ethernet switching, tether interfaces, and topside communications around the deployment.
- Thrusters, grippers, lights, and spares
Thrusters, grippers, lights, and spares
- Discuss T200 or T500 propulsion, manipulators, lighting, controllers, replacement parts, and service support.
Discuss T200 or T500 propulsion, manipulators, lighting, controllers, replacement parts, and service support.
Need manufacturer specifications?
View current BlueROV2 specifications and options on the Blue Robotics website, then speak with Sweep Deep about assembly, integration, training, and project fit.